Walker Tienkung DEX Operation Guide
This document describes the basic flow for using Thinker studio v2.0.x with Walker Tienkung DEX for Pico teleoperation, data collection, quality inspection, and export.
For general installation configuration, service management, and Pico-side operations, please refer to:
Note: The screenshots in this document use Walker Tienkung as an example. The operation flow for Walker Tienkung DEX is the same and can be used as a reference.
Applicable Environment
| Item | Requirement |
|---|---|
| Target Machine | PC with Ubuntu 22.04 |
| System Architecture | amd64 |
| Hardware | Recommended memory ≥ 32 GB, minimum 16 GB |
| Installation Package | deb/thinker-studio_2.0.35_amd64.deb |
Network Configuration
After connecting the target machine and Walker Tienkung DEX with an Ethernet cable, ensure both sides are on the same network segment.
Walker Tienkung DEX factory network segment:
192.168.41.xConfigure the target machine's physical Ethernet port to a static IP in the same network segment, for example:
IP Address: 192.168.41.100
Subnet Mask: 255.255.255.0
Use the following command to check whether the target machine can access the Orin board:
ping 192.168.41.2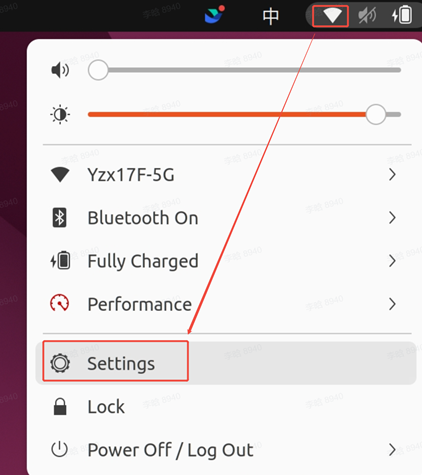 Ubuntu wired network configuration entry
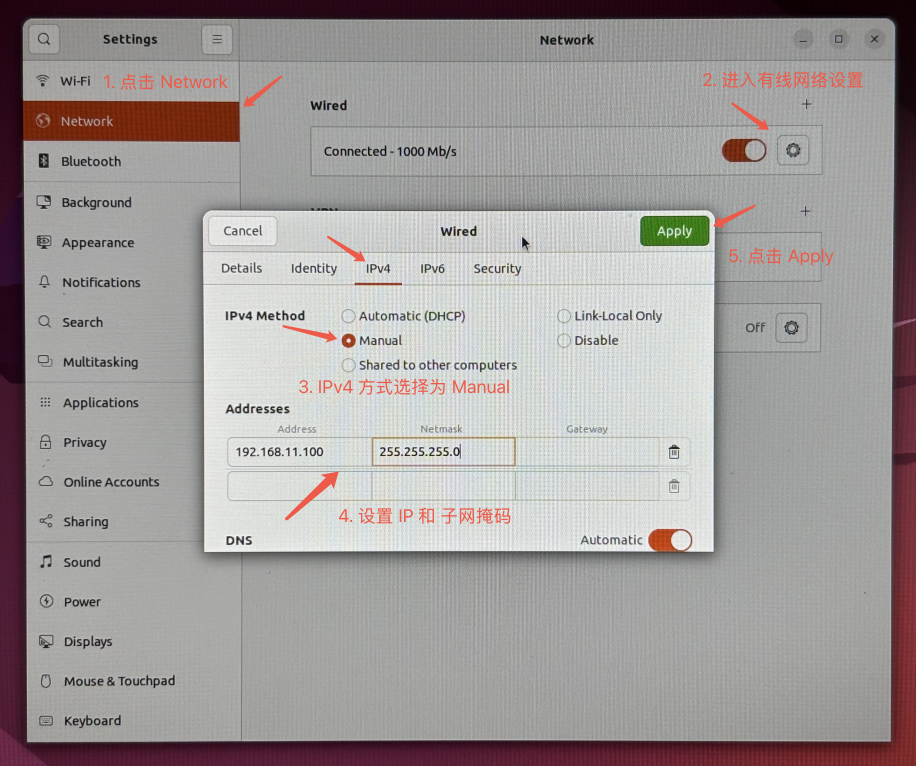 Ubuntu IPv4 manual configuration example
Pre-use Preparation
Please confirm:
- The target machine has Thinker studio installed.
- The target machine has completed network configuration and can access
192.168.41.2. - Walker Tienkung DEX is powered on.
- Pico, body trackers, and remote controller are ready.
Select Robot
Find the Thinker studio icon in the application center on the target machine and click it to open the client.
On the robot selection page, select "Walker Tienkung DEX" to enter the teleoperation page.
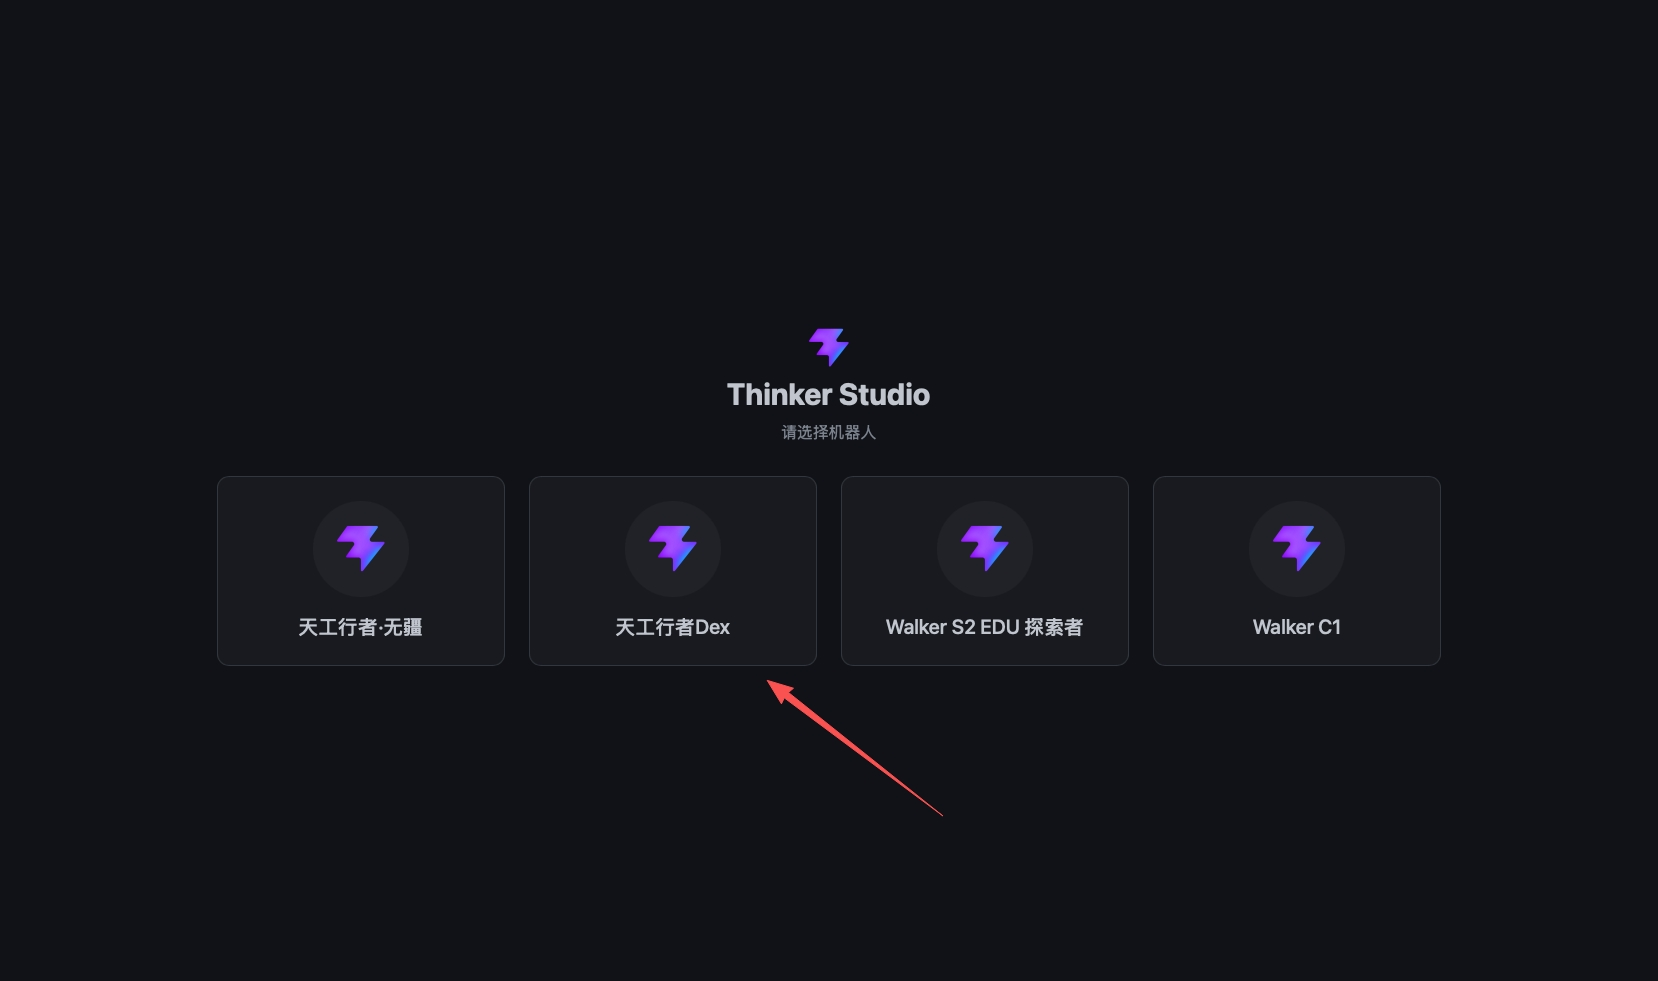 Thinker studio client icon
Start Pico Teleoperation
Start Teleop Service
Start the Teleop Service service in the Thinker studio client.
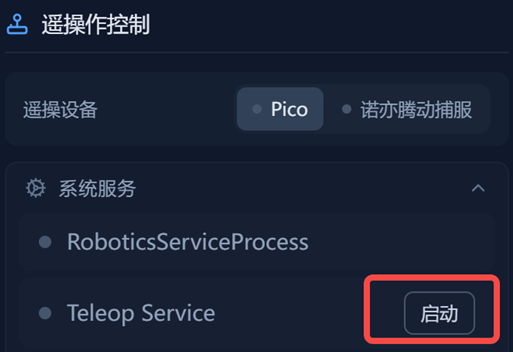 Start Teleop Service
This service is used to receive tracking and control data sent from the Pico side. After the service starts, keep the client page open.
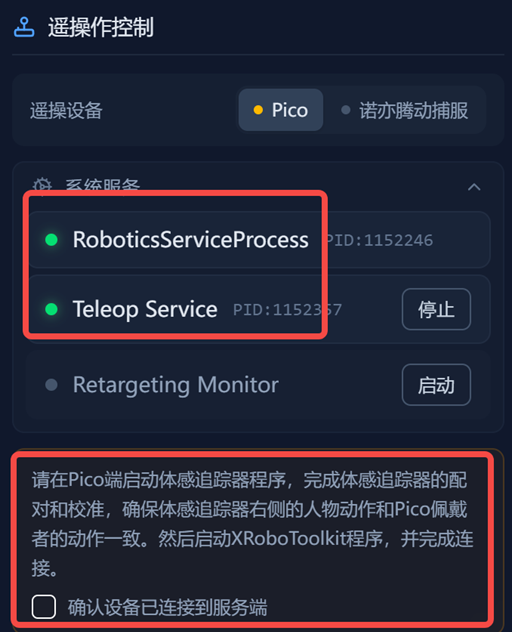 Teleop Service running
Pico-side Operations
For tracker wearing, XRoboToolkit connection, checking Send, and other Pico-side operations, please refer to the Pico Operation Guide.
Start Retargeting Monitor
Start the Retargeting Monitor service in the Thinker studio client.
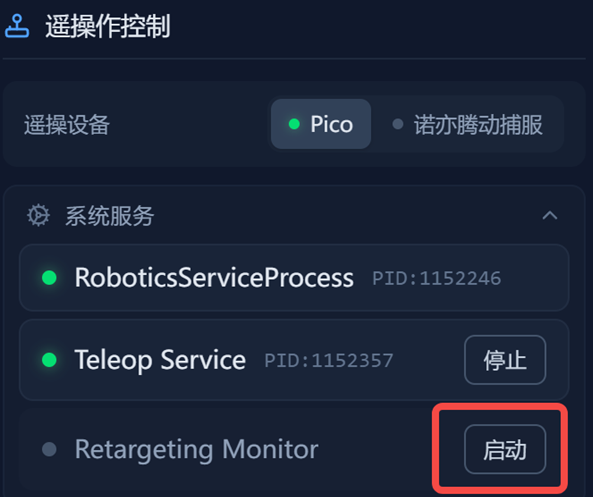 Start Retargeting Monitor
This service is used for motion retargeting monitoring during teleoperation.
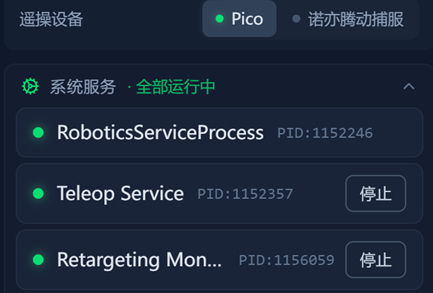 Retargeting Monitor running
Start Teleoperation
Click Start in the teleoperation area of the Thinker studio client.
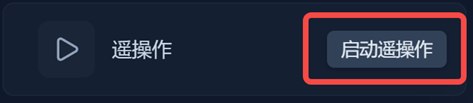 Click to start teleoperation
Important Note:
Currently, Walker Tienkung DEX only supports teleoperation in a suspended state and does not support standing teleoperation. Please start following only when the robot is in a suspended state, and avoid teleoperation in a standing state.
Safety Reminder
After clicking Start, the robot will begin to follow movements. Please confirm that the robot's surrounding environment is safe and spacious, and avoid people or objects entering the robot's motion range before clicking.
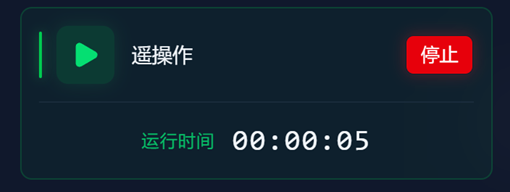 Teleoperation started successfully
End Teleoperation
When ending teleoperation, please operate in the following order:
- Click
Stopin the teleoperation area of the Thinker studio client. - Stop related services, such as
Teleop ServiceandRetargeting Monitor. - If you need to pause Pico control data sending, you can uncheck
SendunderData & ControlinXRoboToolkiton the Pico side.
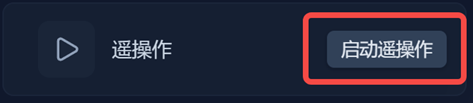 Stop teleoperation
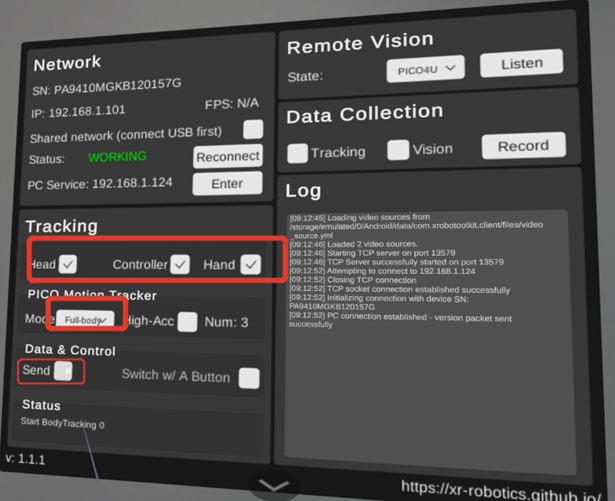 Stop related services
Data Collection
Data collection is used to collect camera data and arm joint angles.
Start Collection
Safety Reminder
Before starting data collection, please confirm that the robot's surrounding environment is safe and spacious, and avoid people or objects entering the robot's motion range.
Click Start in the data collection area of the Thinker studio client to begin collection.
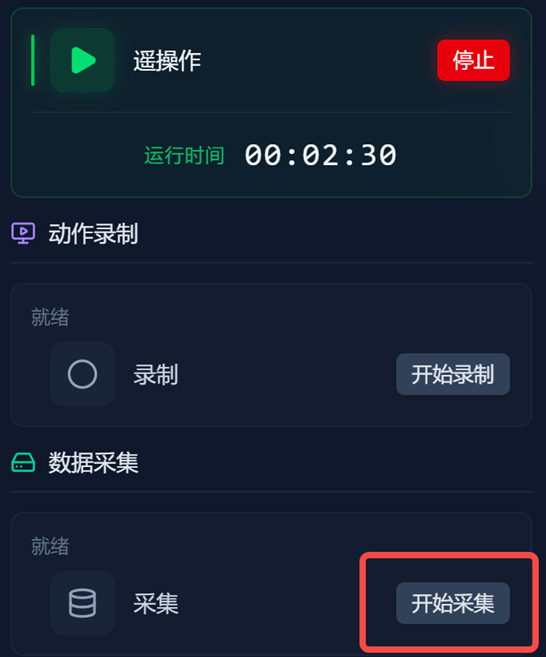 Start data collection
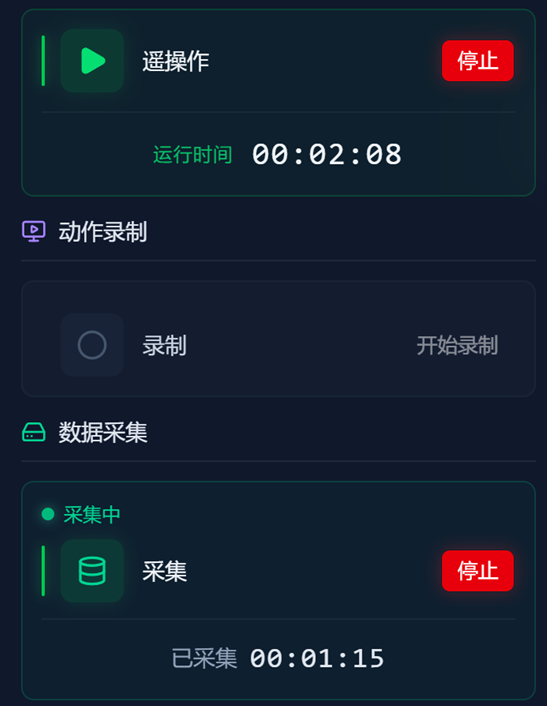 Data collection started successfully
End Collection
Click End in the data collection area to stop collection.
After successful collection, the collected data will be displayed in the collection history area on the right.
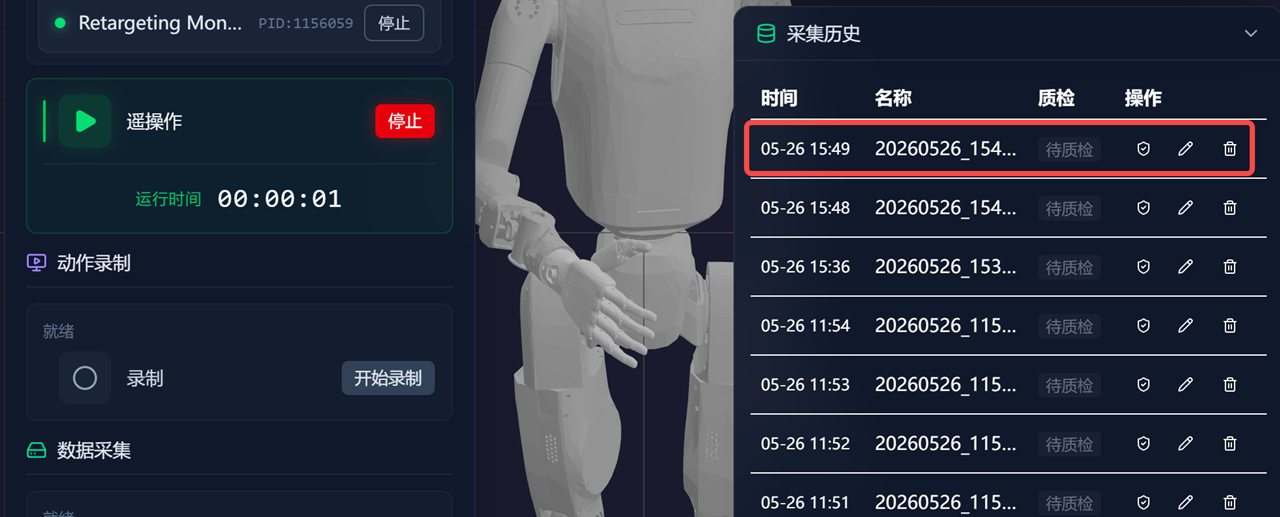 Collection history
Data Quality Inspection and Export
Data Quality Inspection
Select the data to be processed in the collection history and click Quality Check to enter the data quality inspection page.
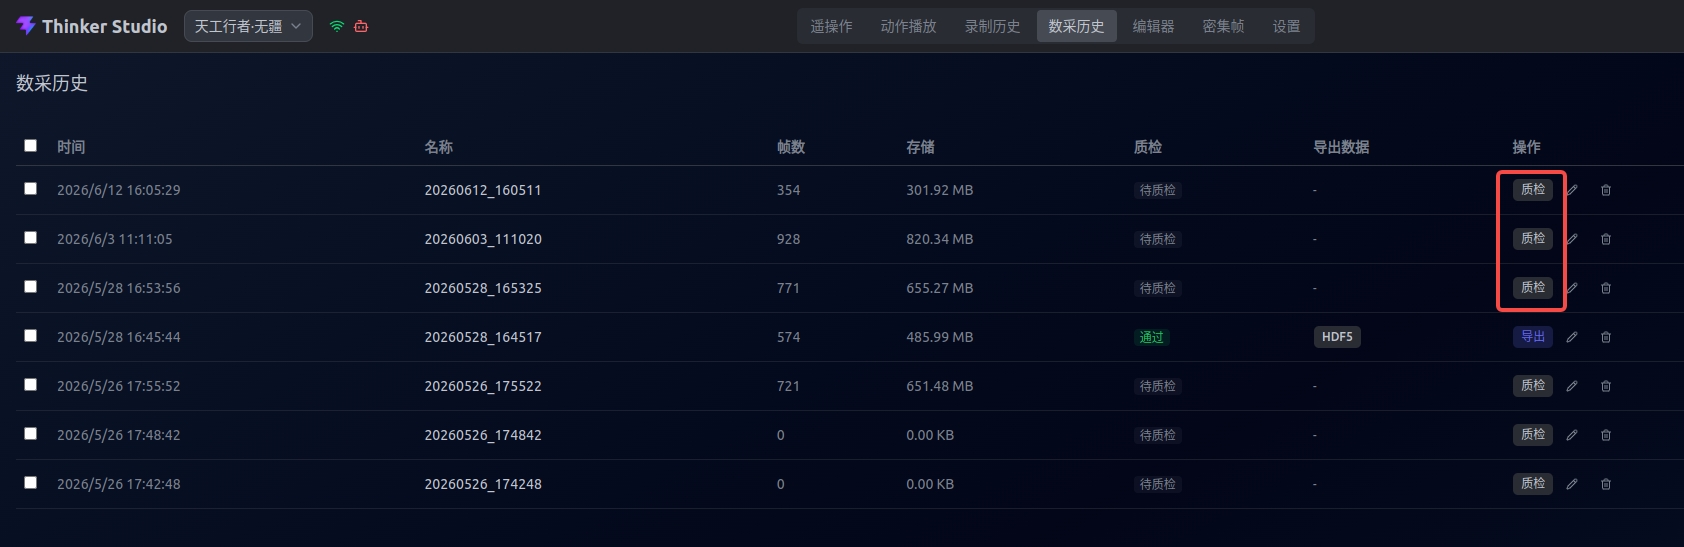 Enter quality inspection
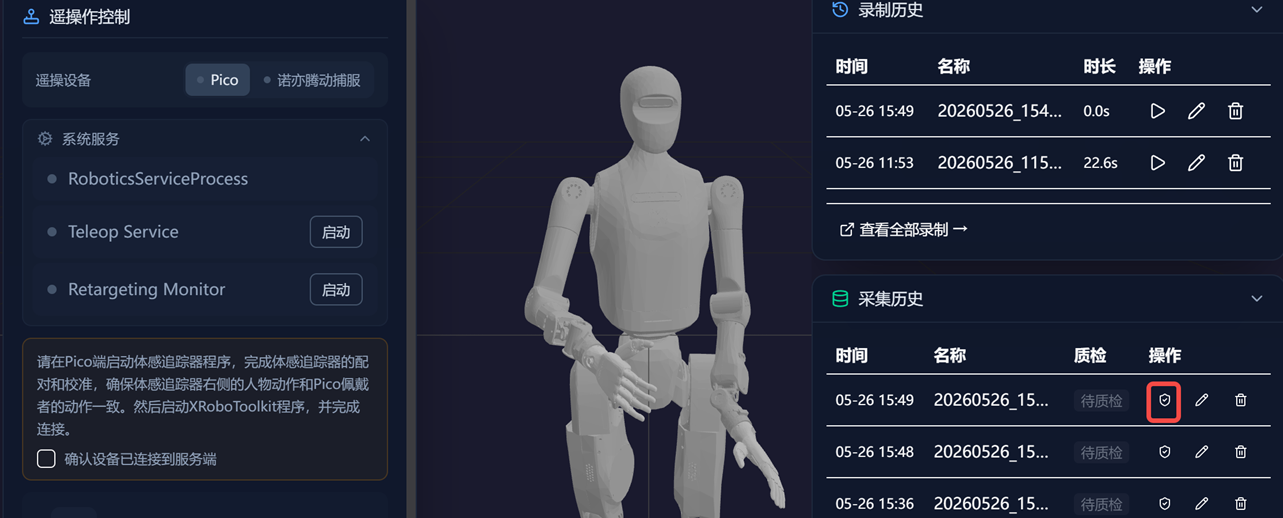 Quality inspection page
The quality inspection page supports adding multiple region frames and adding descriptions for the region frames. Click Submit when finished.
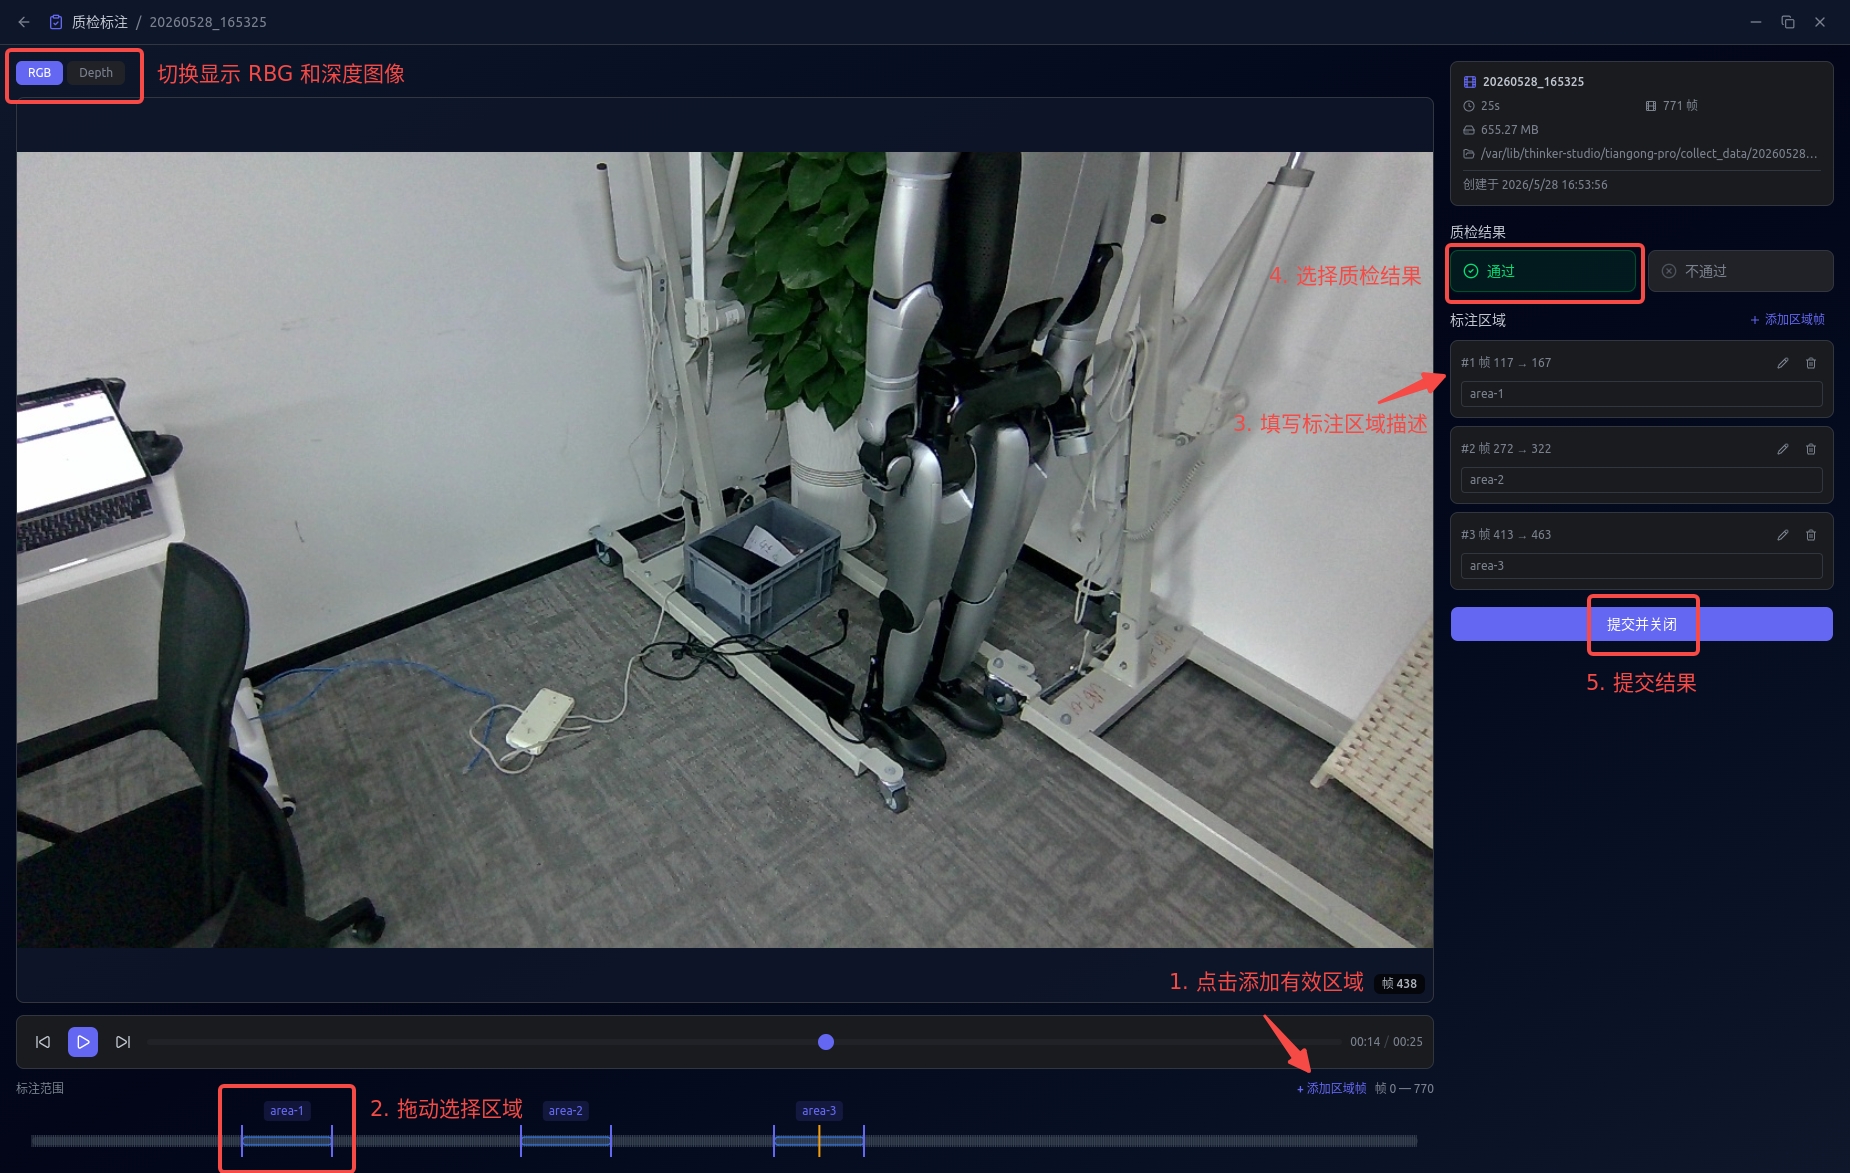 Submit quality inspection description
Data Export
Data that has completed quality inspection will display an Export button.
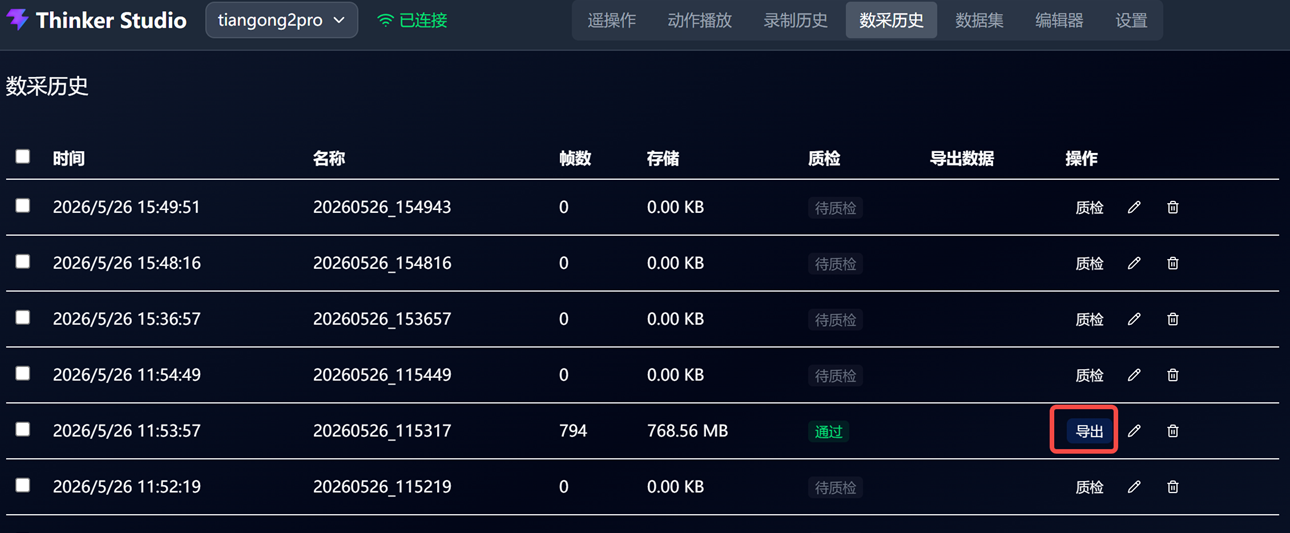 Export button
After clicking Export, select the desired export format. The larger the data volume, the longer the export time.
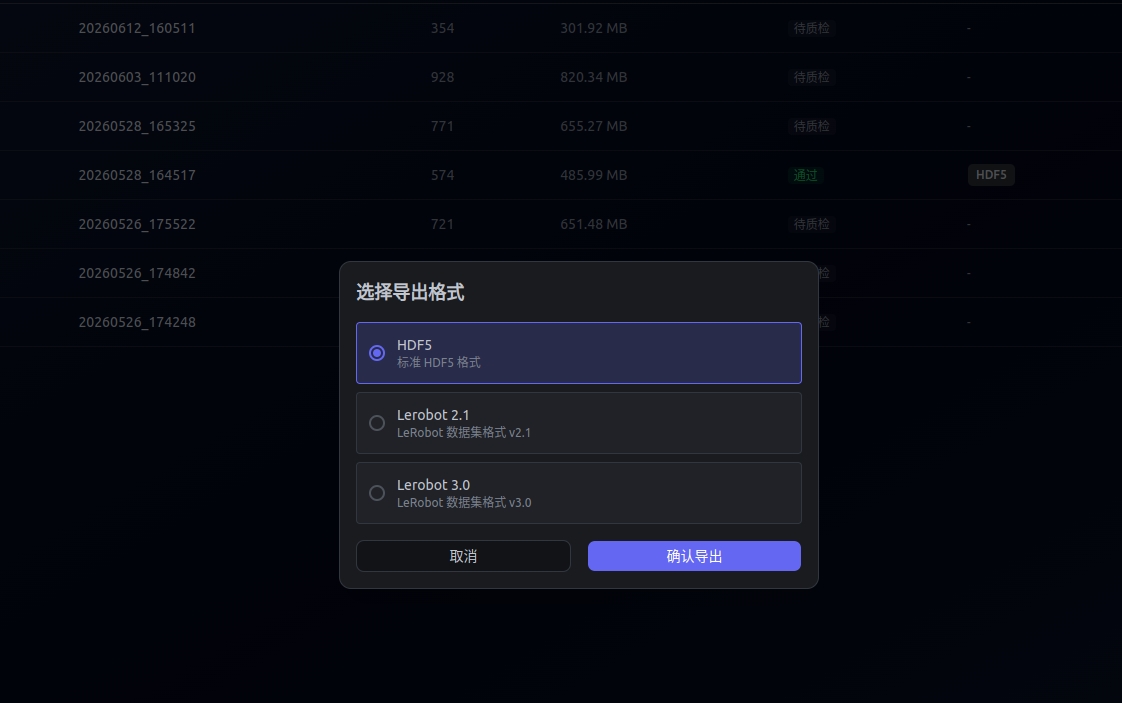 Select export format
After successful export, refresh the page. The page will display the exported data directory, and you can click to copy the directory path.
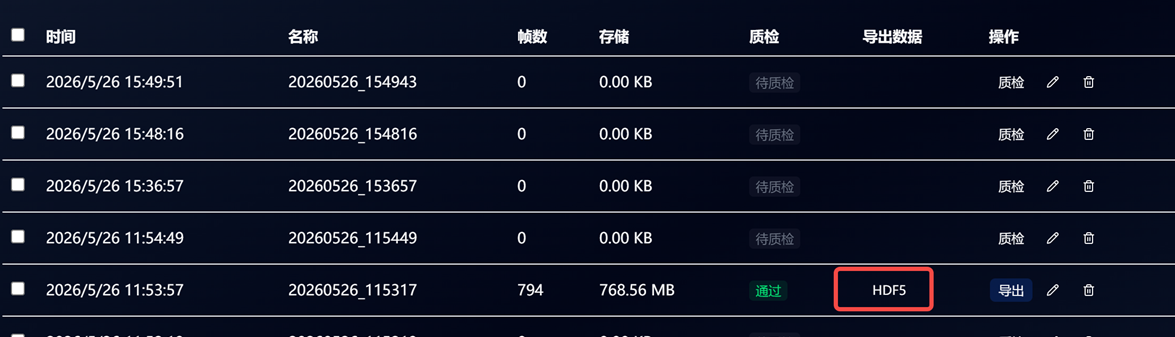 Exported data directory
FAQs
Data collection fails to start
Please check the following items first:
- Whether Walker Tienkung DEX is powered on.
- Whether the target machine can access
192.168.41.2.